

FLL 2023: Bag 14 - Instructions for Audience Delivery - FIRST LEGO League 2023-2024 MASTERPIECE
These are 3D Building Instructions for the Audience Delivery mission model for the FIRST LEGO League 2023-2024 MASTERPIECE competition.
- #1677
- 09 Aug 2023
These are 3D Building Instructions for the Audience Delivery mission model for the FIRST LEGO League 2023-2024 MASTERPIECE competition.

This attachment was intended for and tested on the Gazon, LEGO Education SPIKE Prime competition robot. It is meant to help the robot complete the 9th mission of the FLL Cargo Connect competition.

3D building instructions for the watch television LEGO mission model from the FLL 2022 competition

This is an Inertia triggered attachment build with a LEGO MINDSTORMS Robot Inventor 51515 set. With this attachment we can collect different parts and bring them back to base at FIRST LEGO League competitions. The principle is useful as no additional motors are required for activating this attachment. In the same time it is active which means that it moves and can change it's position in space separately from the robot.. which is useful

These are instructions on how to build the:
You can find more building instructions and tips and tricks about the competition on this page.

These are instructions on how to build the:
You can find more building instructions and tips and tricks about the competition on this page.

These are instructions on how to build the:
You can find more building instructions and tips and tricks about the competition on this page.

Zatter is the big brother of Zat and Zatty. Zatter is here to take the load. It has a large container on its back, suitable for placing different toys inside and playing with them. Built from LEGO SPIKE Core set 45678 + LEGO SPIKE Expansion Set 45680 it was designed by my wife and just slightly improved by me and my colleagues. We spend a good hour or two with the kids placing different plush toys and playing with it.
Play time for a week: About an hour

Това е модул, който прилича на глава на риба. Той използва сензор за допир като уста и иначе е изцяло за красота. Модулът се използва в Писцис - LEGO Mindstorms EV3 робот Риба.


This field has a square canvas size of 1000mm.
The round sumo circe is with an outside diameter of 770mm.
There is a cross to incate the center of the ring for easier measuring to it.
The filed should be printed on a 1000mm X 1000mm canvas with 100% scale and 0 margins.

Building instructions for the transportation stands mission models. The models are used in the Precise driving mission of FLLCasts Off-season Challenge 2019.

This robot is robot based on Roberto Chassis. It is equiped with a pushing rack. You can add something to the rack so it can do some other jobs.
The program for this robot is at programs/ajk7i1-roberto-with-rack-for-pushing-to-the-left-and-right-side-vex-iq-robot.

In this 3D scheme, you can see how the motor driver is connected to the Raspberry Pi and to the motor. Follow the steps in the instructions one by one and you will have successfully connected the motor to the Raspberry PI

Инструкции за четвъртия модул, версия 1, на робота Ugbroid - задни колела.

- note that I have added two angled beams and an axle to illustrate how you could use the slide as an active attachmen;

You can attach a frame around the front wheels to make them more stable and to allow for better aligning. The module extends the front wheel built at BigDaddy Front - front wheels mechanism module for a large LEGO Mindstorms Competition Robot

The rotation frame requiers an NXT large double gear wheel that is not available at the EV3 set. You can use the instructions below to construct a similar mechanism from Mindstorms EV3 set


Тази конструкция трябва да се свали, за да се построи.
От три кутии може да се построи робот. Нека учениците да строят модули от различните кутии, които да сглобят заедно в един робот.
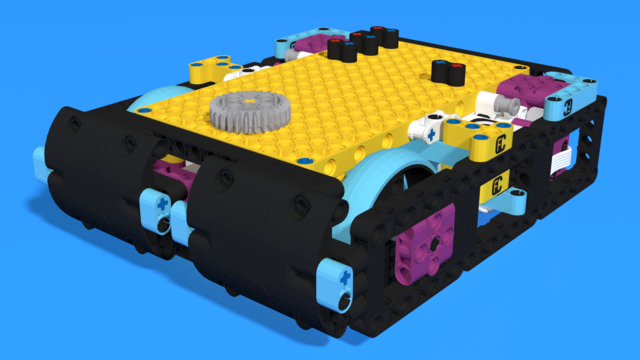
This is the beautiful version of the robot. :) It is more likely for having fun, than use it for competition. It have beautiful front that is not very useful for a competition, due to larger attachments, but it is a little bit more stable than the "uglier" and smaller version. :)
This robot is very low, relatively compact and very hard to control. To move as desired it must carry heavy attachment between its front tires. It also needs often clearing of its rear balls and the beads where they are positioned. Ones that is done the robot becomes pretty accurate. If you change the front tires with tires that have higher grip than the ones in the Spike set it becomes precious. Spike Prime Tires don't have grip but looks good. :)
It is ideal to learn how to control robots in real world applications where nature plays bad jokes on the engineers.
The two color sensors look up so it can see the attachment control parts, so it decides what part of the program to run. It have only one attachment motor with only 1 attachment element - 28 Teeth and 4 holes Gear.
